 Back to home
Sources
Contributors
Written by Nima Kamali and Ava Poole.
Special thanks to X.
Actuator
Benjamin Katz (2018), Figure 2-2 — motor, planetary transmission, bearings, and controller within one actuator module.
Mini-Cheetah-Actuator by Saketh vegesna — mechanical CAD. MIT License.
moteus C1 by mjbots — controller CAD, via GoForFab. Apache License 2.0; KiCad library license.
Research footage
- 01
Axioms of robotics development
DHL / Boston Dynamics — Boston Dynamics Stretch unloading cardboard boxes inside a DHL trailer.
- 02
The fundamental flywheel of robotics
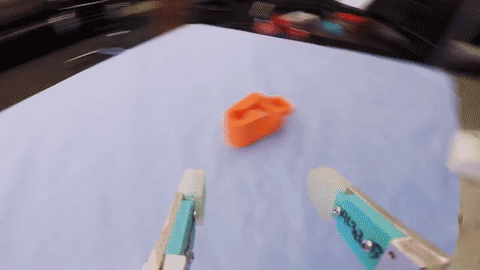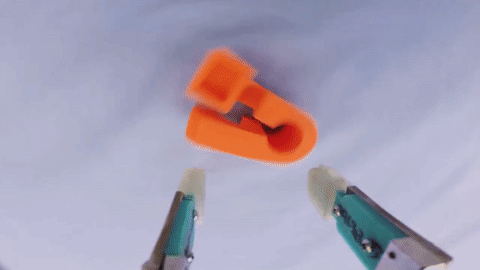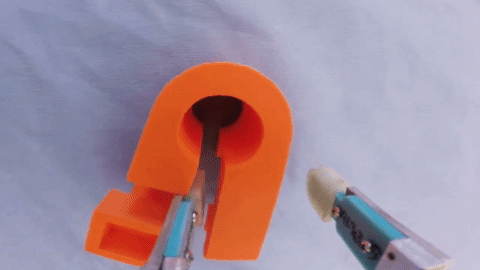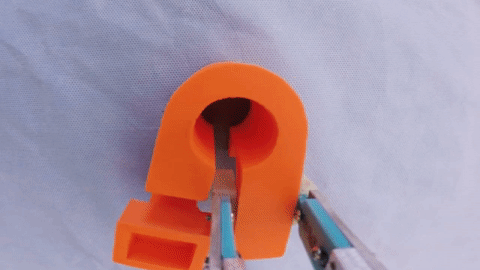
UC Berkeley AUTOLAB / BAIR; Jeff Mahler — Real Dex-Net robot demonstration: a gripper picking up an orange object.
- 03
Data scaling is finally working
Dyna Robotics — A grid of robot camera views showing Dyna manipulation tasks.
- 04
Failure as an asset
Physical Intelligence — Physical Intelligence robot arms working at an espresso station.
- 05
What humans got right
mimic robotics — A mimic robotic hand using a small tool for precise manipulation.
- 06
- 07
Hardware gaps
mimic robotics — A real robotic finger backdrivability test, demonstrating compliant hardware.
- 08
Economic vs human value
Figure — A Figure humanoid performing household work at a kitchen sink.
Graph sources
- LLM performance
- METR task-completion horizons — human task duration associated with 80% model success. Published results.
- Humanoid deployment
- Counterpoint Research, 2025 installations and 2026 shipments. Shipments provide the deployment proxy.
- Robot deployment and specialist robots
- IFR World Robotics 2026 and historical charts — annual industrial robot installations.
- Interaction data
- Released training episodes from RoboNet, DROID, and AgiBot World. AgiBot Beta replaces its Alpha subset.
- Hardware cost
- Bank of Japan producer-price index, Robots, excluding consumption tax — series PRCG20_1201350029. Lower values mean lower prices.
Historical trajectories combine published observations with interpolation and backward extensions. Display values use one shared compression, with 2025 set to 100 and the ceiling set to 10,000. Source measurements and curve shapes remain unchanged; the compressed values show relative trajectories rather than literal growth multiples.
Dashed lines are authored scenarios. Their growth, timing, and plateaus are assumptions, informed by AI 2040’s takeoff forecast and scaling strategy. The humanoid and total-deployment curves follow the modeled LLM trajectory; they are not publisher forecasts.